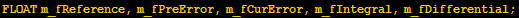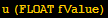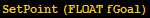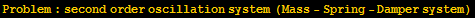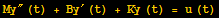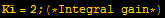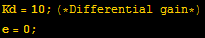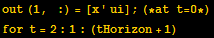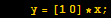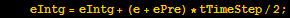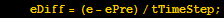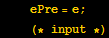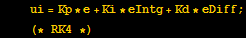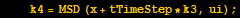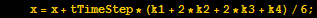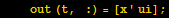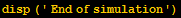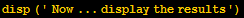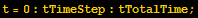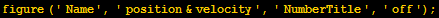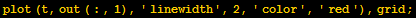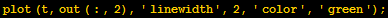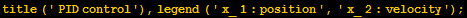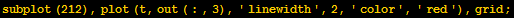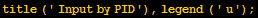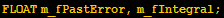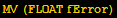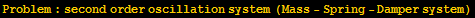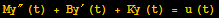
PID Feedback

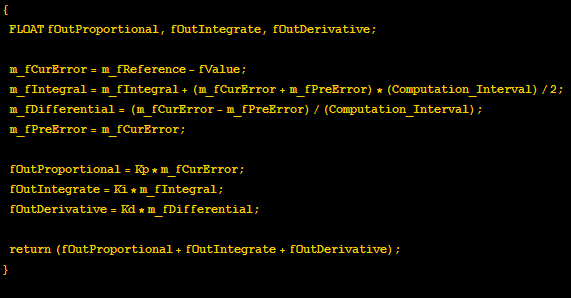
Proportional plus Integrate plus Derivative

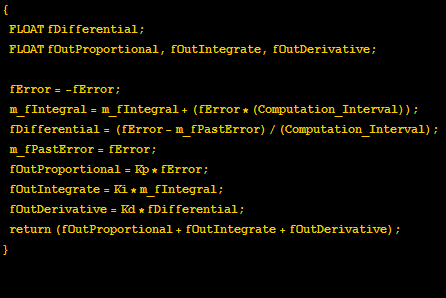
Kp : Propotional

Ki : Integral

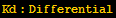
Kd : Differential

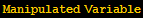
Manipulated Variable

FLOAT m_fReference, m_fPreError, m_fCurError, m_fIntegral, m_fDifferential ;

u (FLOAT fValue)

FLOAT m_fNowValue, m_fPastValue, m_fManipulated ;

SetPoint (FLOAT fGoal)

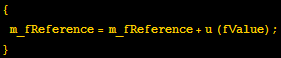
{m_fReference = m_fReference + u (fValue) ; }

Example of PID control

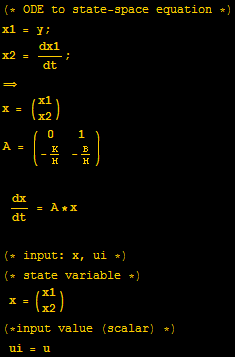
Problem : second order oscillation system (Mass - Spring - Damper system)

My^″ (t) + By^′ (t) + Ky (t) = u (t)

close all

clear all

clc

disp (' Example for PID controller test ') ;

k1 =[0 0] ' ;

k2 =[0 0] ' ;

k3 =[0 0] ' ;

k4 =[0 0] ' ;

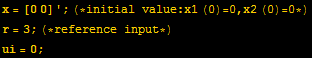
x =[0 0] ' ; (*initial value : x1 (0) = 0, x2 (0) = 0*)r = 3 ; (*reference input*)ui = 0 ;

out = zeros (tHorizon + 1, 3) ;

PID control
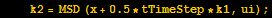
Kp = 5 ; (*Propotional gain*)

Ki = 2 ; (*Integral gain*)

Kd = 10 ; (*Differential gain*)e = 0 ;

ePre = r ;

eIntg = 0 ;

eDiff = 0 ;

out (1, :) =[x ' ui] ; (*at t = 0*)for  t = 2 : 1 : (tHorizon + 1)

    y =[1 0] * x ;

    e = r - y ;

    eIntg = eIntg + (e + ePre) * tTimeStep/2 ;

    eDiff = (e - ePre)/tTimeStep ;

    ePre = e ; <br />    (* input *)

    ui = Kp * e + Ki * eIntg + Kd * eDiff ; <br />    (* RK4 *)

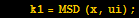
    k1 = MSD (x, ui) ;

    k2 = MSD (x + 0.5 * tTimeStep * k1, ui) ;

    k3 = MSD (x + 0.5 * tTimeStep * k2, ui) ;

    k4 = MSD (x + tTimeStep * k3, ui) ;

    x = x + tTimeStep * (k1 + 2 * k2 + 2 * k3 + k4)/6 ;

    out (t, :) =[x ' ui] ;

end

disp (' End of simulation ')

Display

disp (' Now ... display the results ')

t = 0 : tTimeStep : tTotalTime ;

figure (' Name ', ' position& velocity ', ' NumberTitle ', ' off ') ;

subplot (211)

hold on

plot (t, out (:, 1), ' linewidth ', 2, ' color ', ' red '), grid ;

plot (t, out (:, 2), ' linewidth ', 2, ' color ', ' green ') ;

title (' PID control '), legend (' x_1 : position ', ' x_2 : velocity ') ;
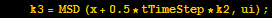
hold off

subplot (212), plot (t, out (:, 3), ' linewidth ', 2, ' color ', ' red '), grid ;

title (' Input by PID '), legend (' u ') ;

disp (' END ') ;

PID(Proportional plus Integrate plus Derivative) Feedback
Manipulated Variable

FLOAT m_fPastError, m_fIntegral ;

MV (FLOAT fError)

FLOAT m_fNowValue, m_fPastValue, m_fManipulated ;

SetPoint (FLOAT fGoal)

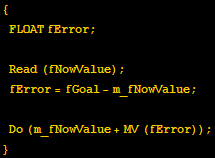
{FLOAT fError ; Read (fNowValue) ; fError = fGoal - m_fNowValue ; Do (m_fNowValue + MV (fError)) ; }

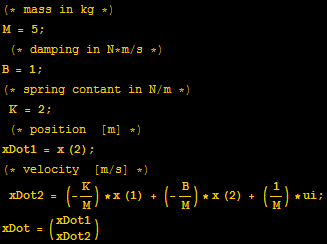
function xDot=MSD(x,ui)

Problem : second order oscillation system (Mass - Spring - Damper system)

My^″ (t) + By^′ (t) + Ky (t) = u (t)