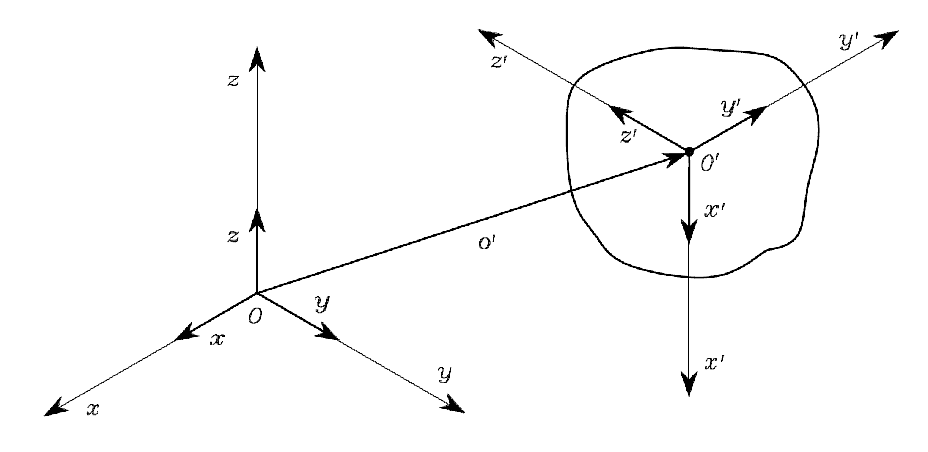
Representation of orientation
Pose of a Rigid Body
Position

Orientation
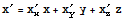
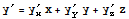
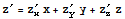
ROTATION MATRIX
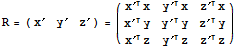


Analysis on Position And Orientation
Cartesian Coordinate (직교좌표계)

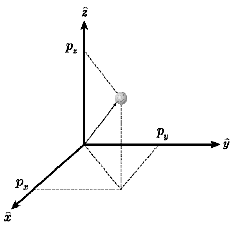
One Point P Vector
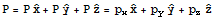
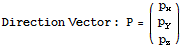
Representation of a vector
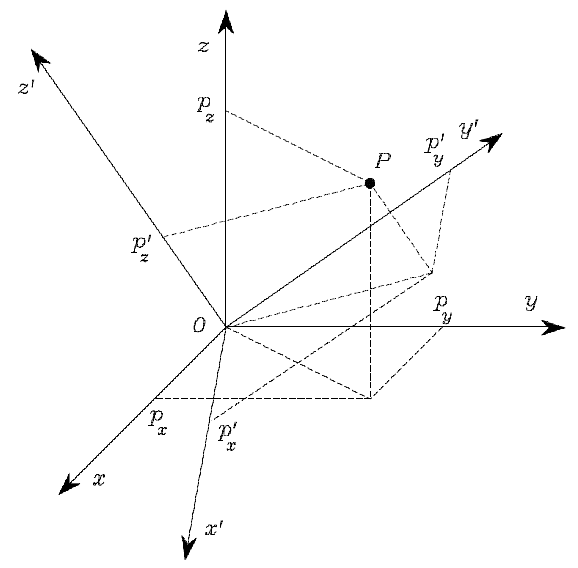


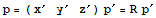

Example
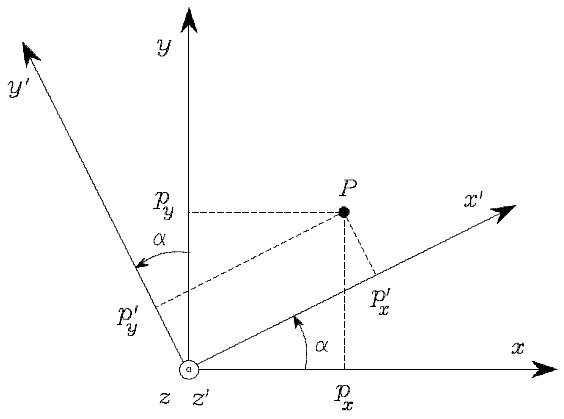
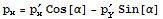
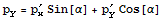

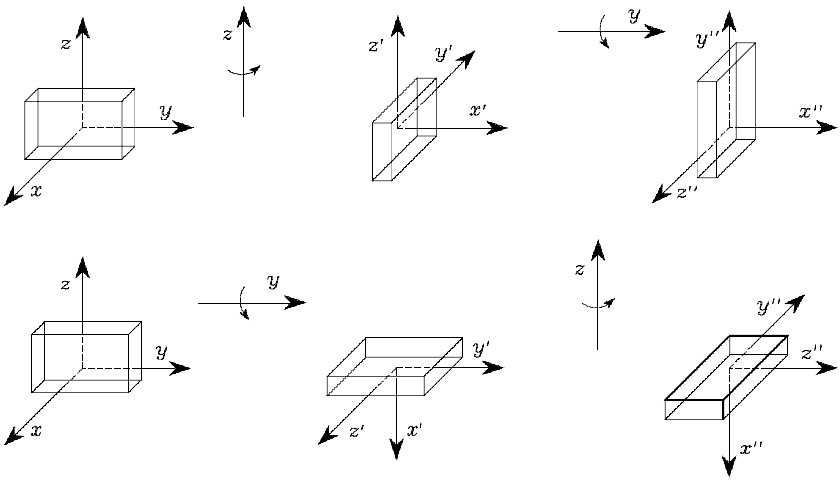
Elementary Rotations
2D Rotation
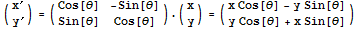
3D Rotation
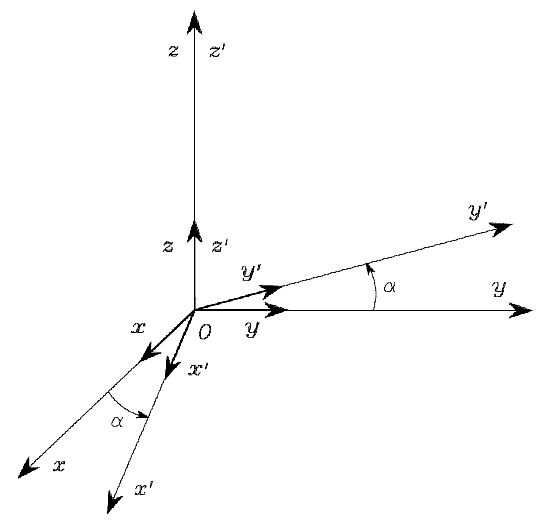
rotation of α about z
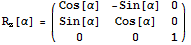
rotation of β about y
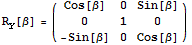
rotation of γ about x
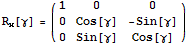
위치 표현 (Position and Orientation)
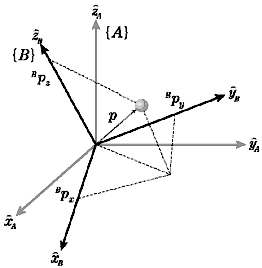
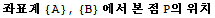
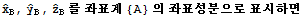
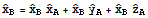

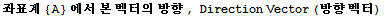

상대 개념 위치
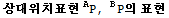
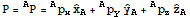
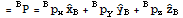
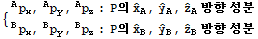
3D Orthonormal Basis → Unit Vectors

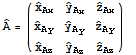
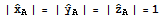
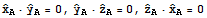

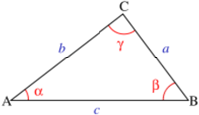
Low of Cosines
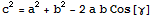
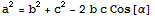
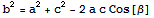
Inner Product Space
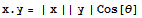
Half-Angle Identities
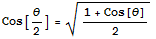
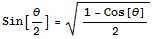
연속좌표변환: 절대변환과 상대변환
이동좌표계 (moving frame)

고정좌표계 (fixed frame)
절대변환 (absolute transform)
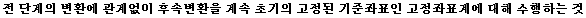
상대변환 (relative transform)
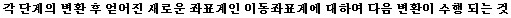
좌표계{A}와{B} 사이의 변환을 나태내는 동차변환행렬
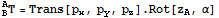
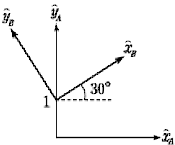
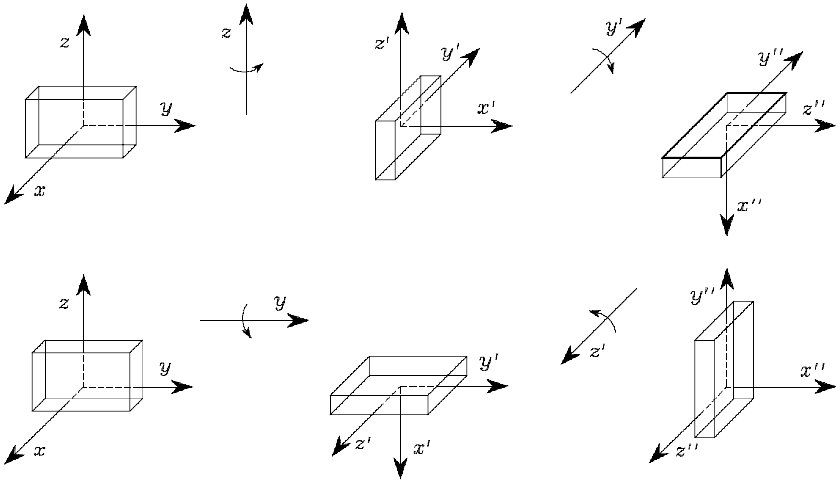
O: 이동좌표계를 따라 병진 후 이동좌표계에 대해 회전
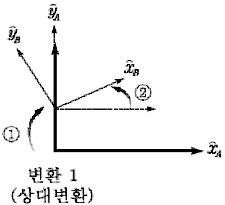
X: 이동좌표계를 따라 회전 후 이동좌표계에 대해 병진
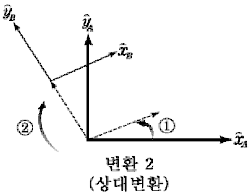
O: 고정좌표계를 따라 회전 후 고정좌표계에 대해 병진
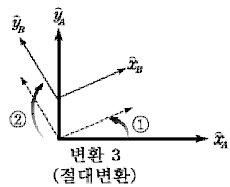
X: 고정좌표계를 따라 병진 후 고정좌표계에 대해 회전
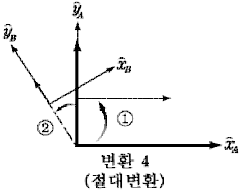
올바른 변환을 나타내는 조합
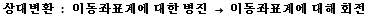

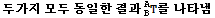
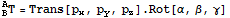
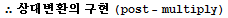
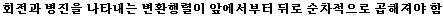
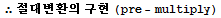


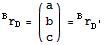


방위의 다른 표현
방위의 표현

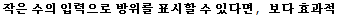
EULER ANGLES
rotation matrix

minimal representation of orientation
Euler angle과 Roll-Pitch-Yaw 방법

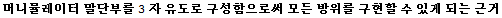
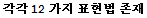
Z-Y-Z 오일러 각
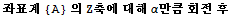
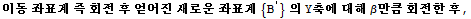
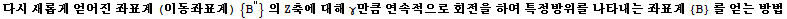
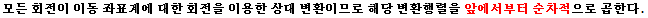
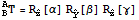
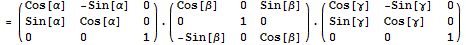
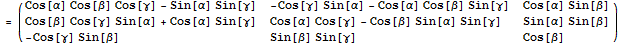
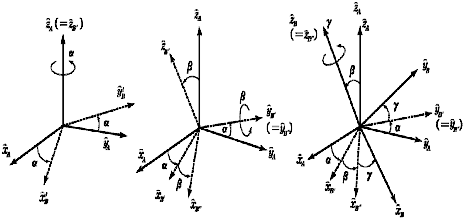
ZYZ angles
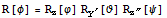
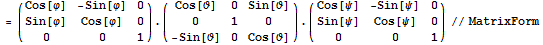
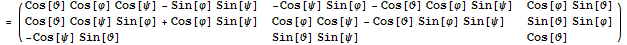
Inverse problem
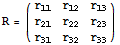
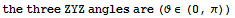
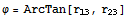
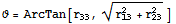
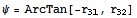
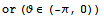
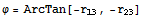
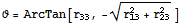
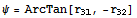
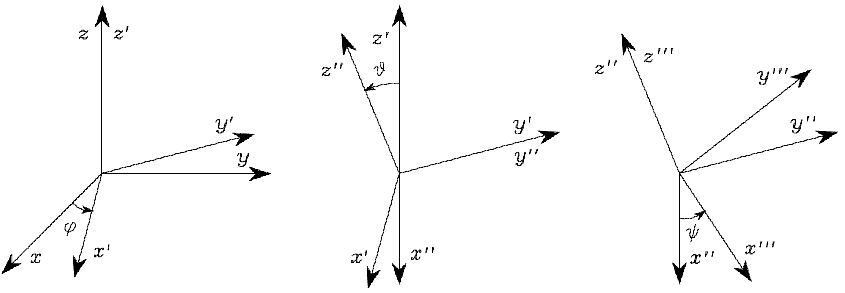
Z-Y-X 오일러 각 (이동 좌표계)
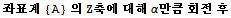
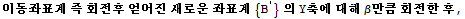
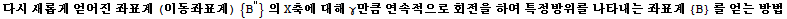
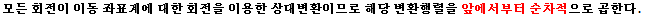
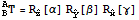
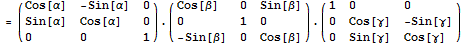
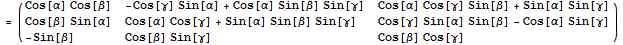
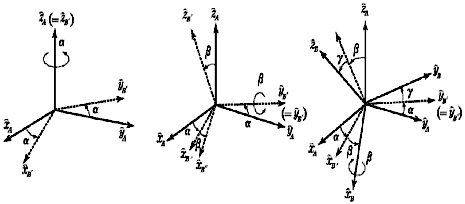
Current frame rotation

Roll-Pitch-Yaw (고정 좌표계)
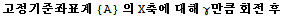
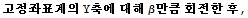

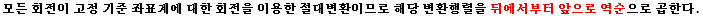
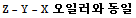
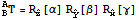
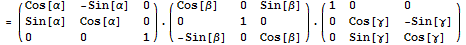
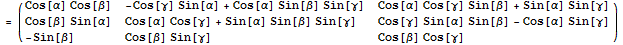
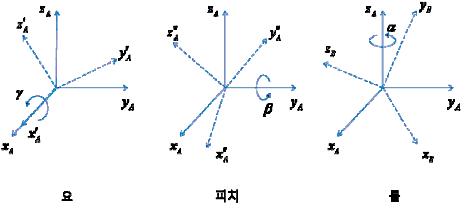
Fixed frame rotation

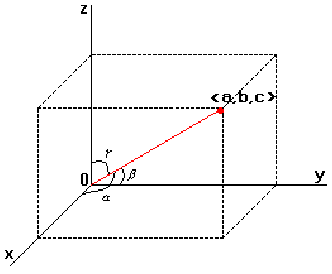
Direction Cosine
단위벡터의 내적→두 벡터 사이 가의 코사인 값
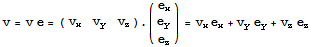
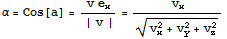
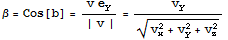
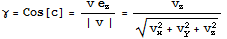
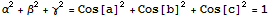
Rotation Matrix  R
Rotation Matrix
좌표계{A}에 대한 좌표계{B}의 회전행렬
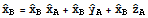
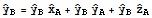
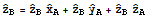
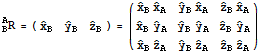

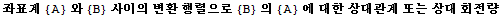

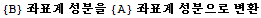
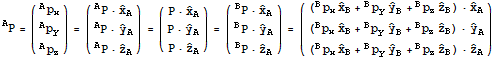
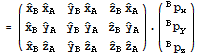

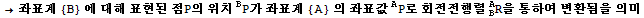
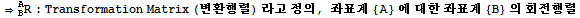
회전행렬의 성질 ( R=

 =
 R)
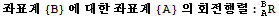
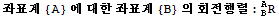
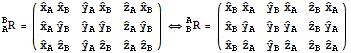

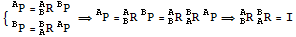

Cartesian coordinate (직교좌표계)
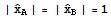
Inner Product Space
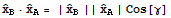
Low of Cosines
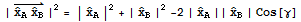
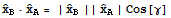
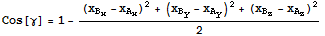
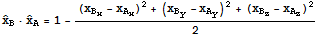
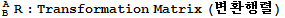
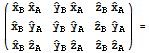
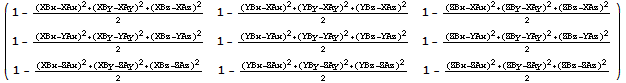
방위의 표현: 회전행렬
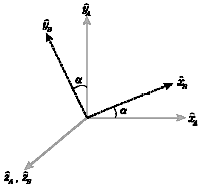
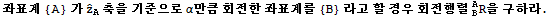
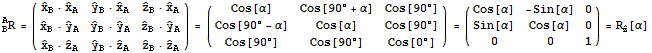
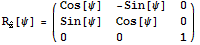
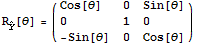
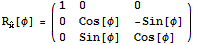
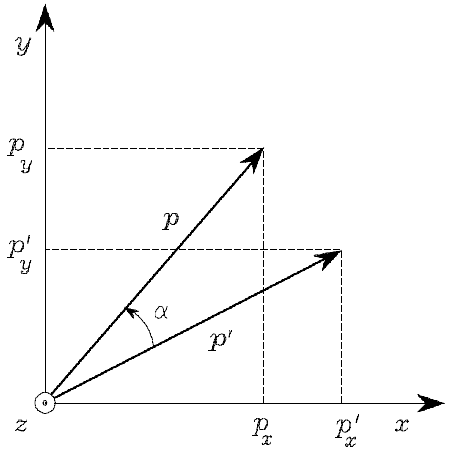
Rotation of a vector


Example
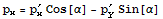
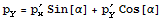


Composition Of Rotation Matrices
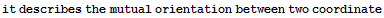
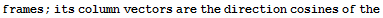
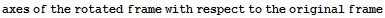
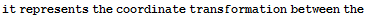
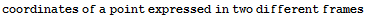
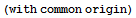
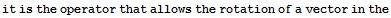
Composition Of Rotation Matrices


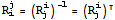
Mathematica
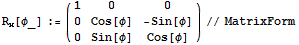
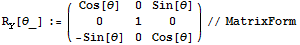
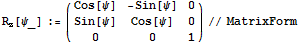
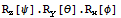
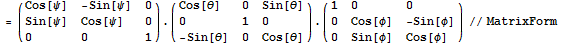
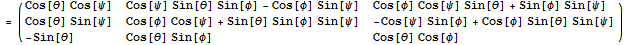
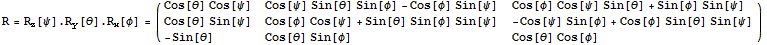
Rotation Matrix and Small Angels
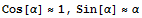
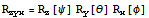
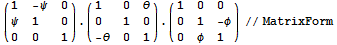
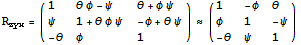
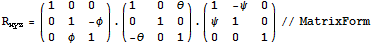
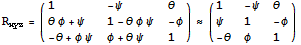
Roll: φ
Pitch: θ
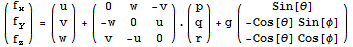
계산
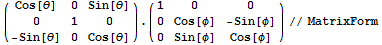
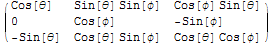
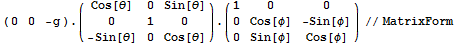
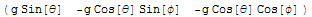
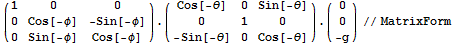
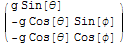
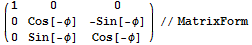
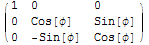
yaw: φ

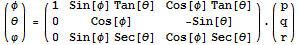
rotation vector: Roll: φ, Pitch: θ, yaw: ψ
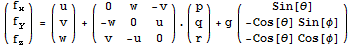
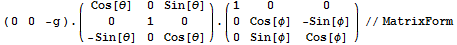
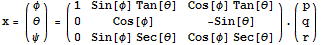
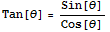
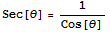
Euler Angle
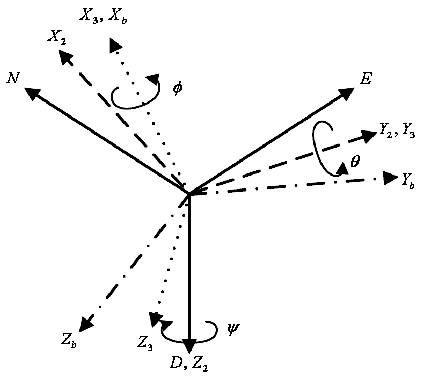
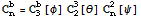
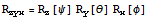
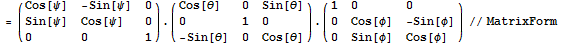
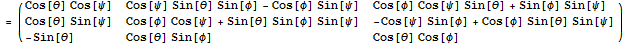
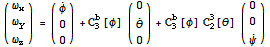
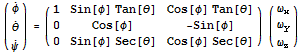
Derivation
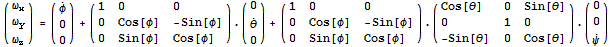
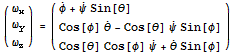
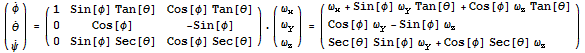
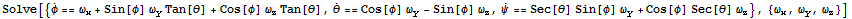
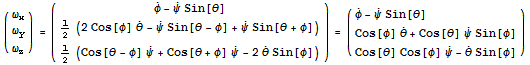
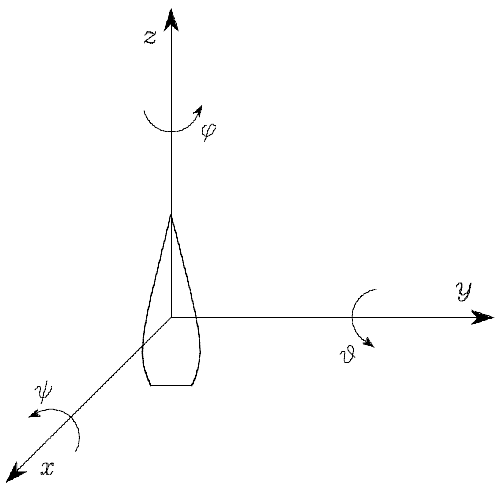
RPY angles
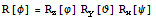
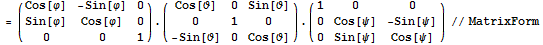
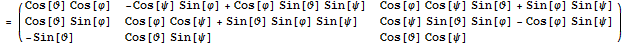
Euler Angle (Roll φ  , Pitch θ
 , Yaw ψ
 , ZYX) → Rotation Matrix
 R
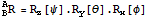
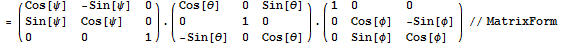
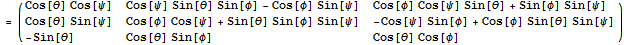
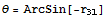
Inverse problem
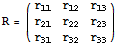
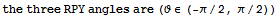
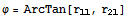
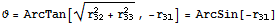
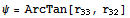
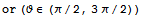
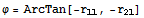
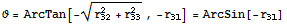
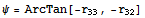
θ (Pitch) = π/2, Cos[θ]≈0
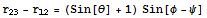
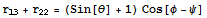
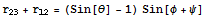
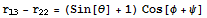
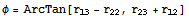
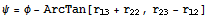
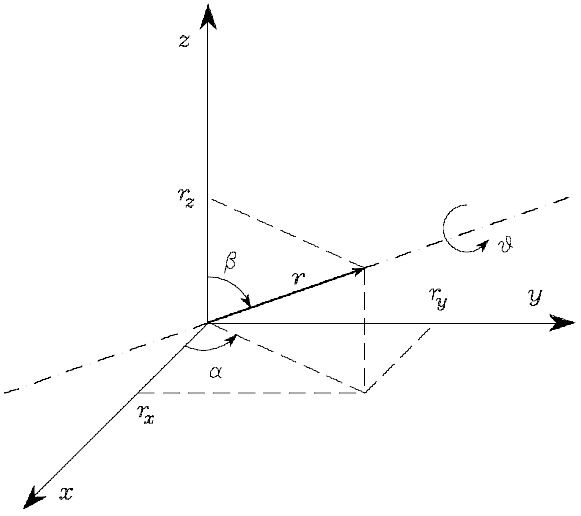
Angle and Axis
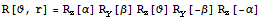
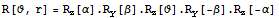
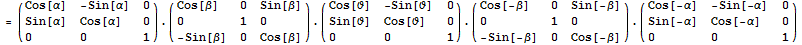
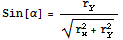
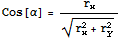
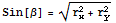

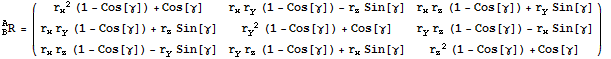
유도
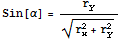
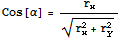
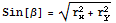

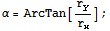
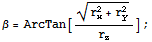
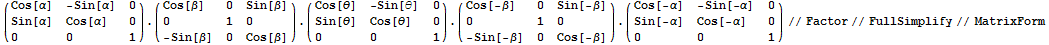
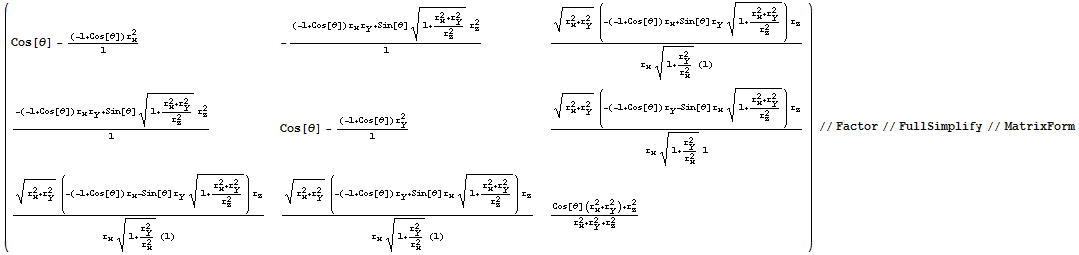
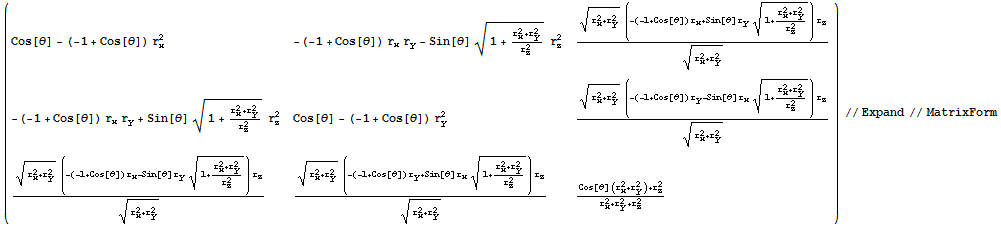
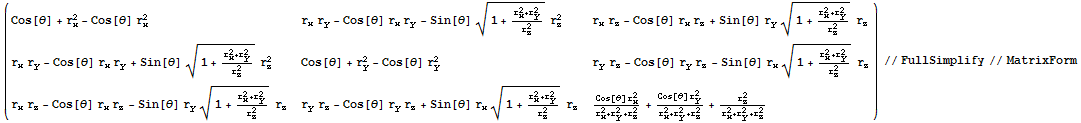

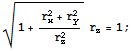
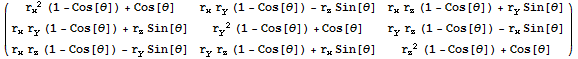
Inverse problem
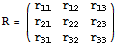
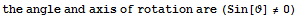
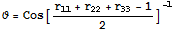
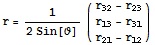

Angle θ and Axis r

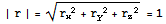
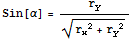
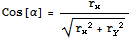
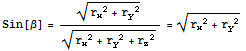
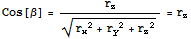
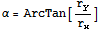
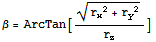
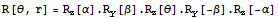
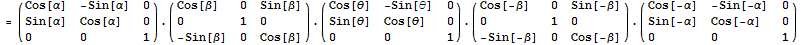
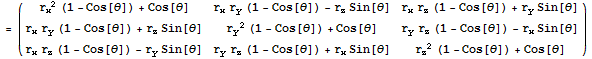
Rotation Matrix → Angle θ and Axis r
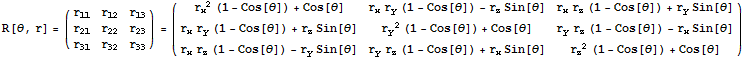
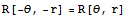
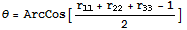
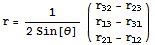
유도
1

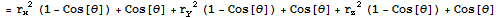
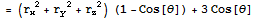
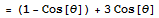

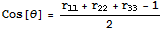
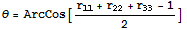
2

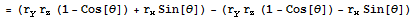


3

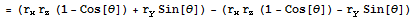


4

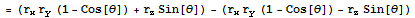


5
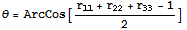
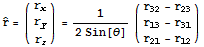

Quaternion → Rotation Matrix
Euler axis

Angle

Rotation Matrix
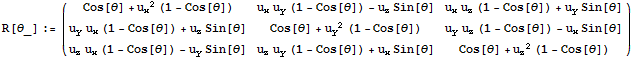
Concisely
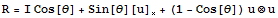

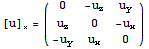
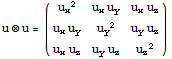
Quaternion Representation
A quaternion is a four-dimensional complex number
An arbitrary orientation of frame B relative to frame A

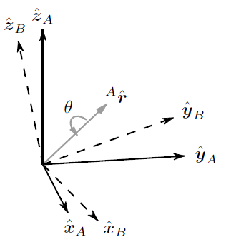
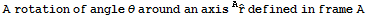
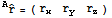
normalized four-dimensional vector
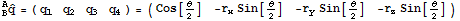
4parameter representation ρ={η,ε}


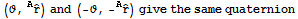
quaternion extracted from  =


the quaternion paramentrization obeys
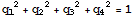
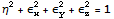
hypercomplex numbers {i,j,k}
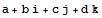


2x2 Complex Matrices, The quaternion a + b i + c j + d k
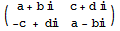
A quaternion conjugate
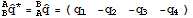
A quaternion product ⊗

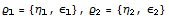
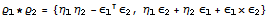
Hamilton rule
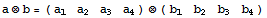
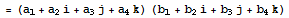
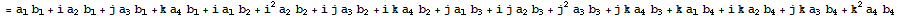
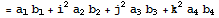
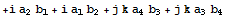
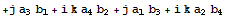
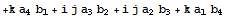
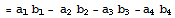
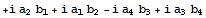
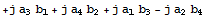
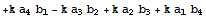
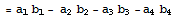
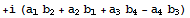
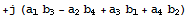
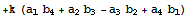
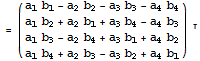
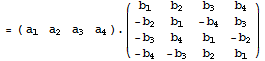
Euler axis


Angle

Vector's Elements


Inverse problem
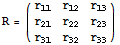
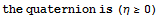
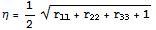
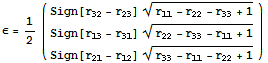
A three dimensional vector - Same vector from frame A to frame B
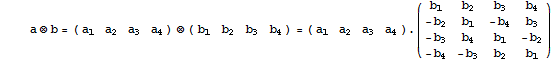
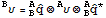
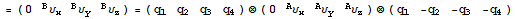
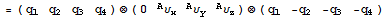
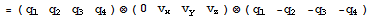
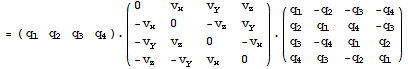
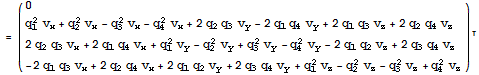
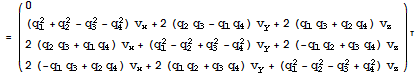
0
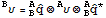
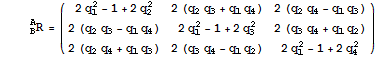
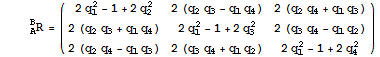
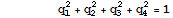

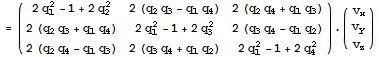
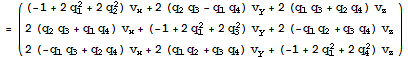
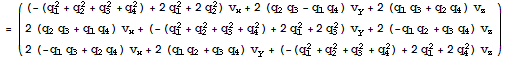
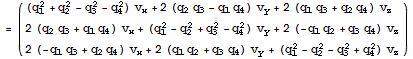
Rodrigues formula
Vector

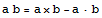
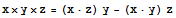
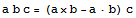
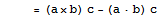
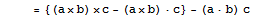
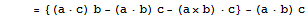
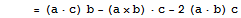
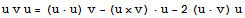
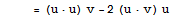
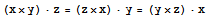
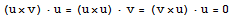
1
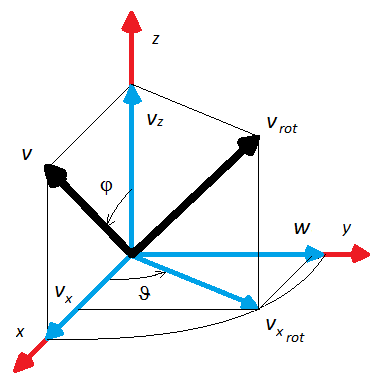
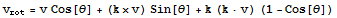
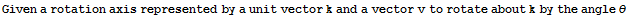
Vector Projection of v on k
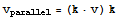
Vector rejection of v from k
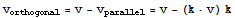
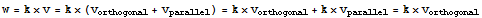
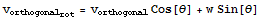
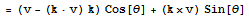
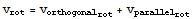
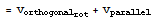
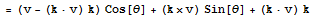
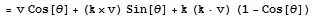
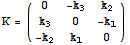

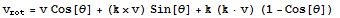
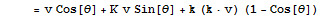
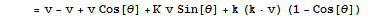
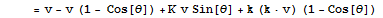
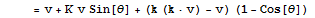
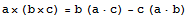
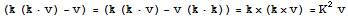
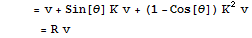
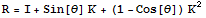

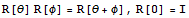
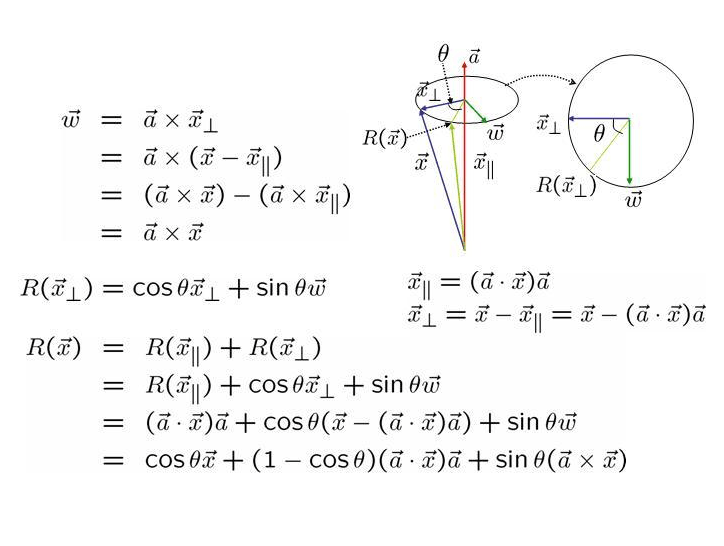
1
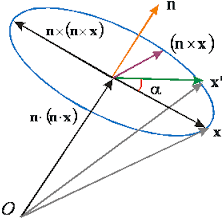
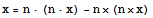
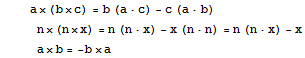
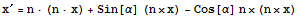
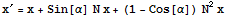
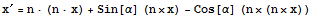
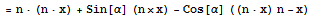
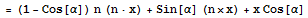
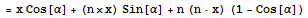
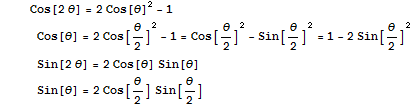
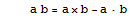
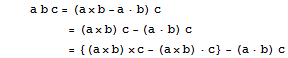
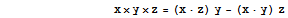
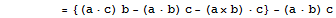
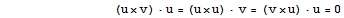
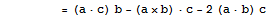
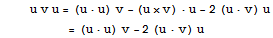
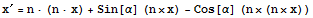
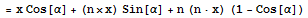
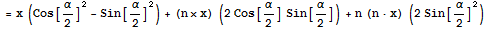
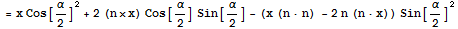
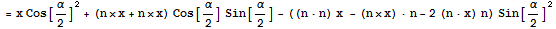
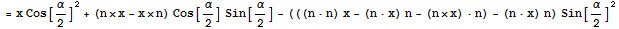
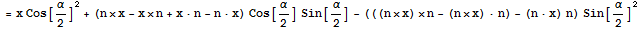
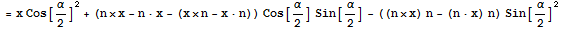
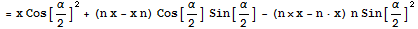
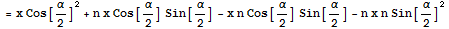
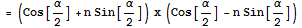

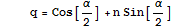
Axis/Angle → Rotation matrix→ Orientation 

Axis/Angle → Rotation Matrix  R
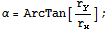
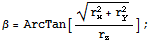
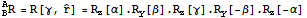
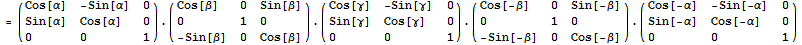
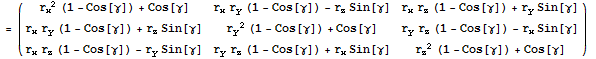
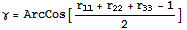
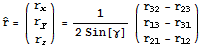
Orientation 
 → Axis/Angle → Rotation Matrix
 R
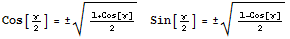
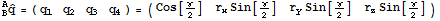
1
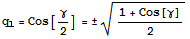
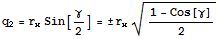
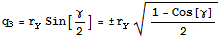
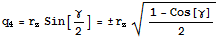
2
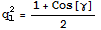
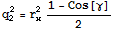
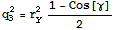
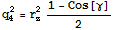
3
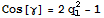
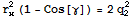
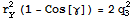
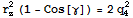
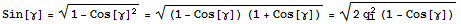
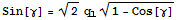
4
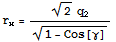
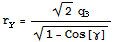
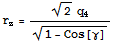
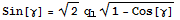
5
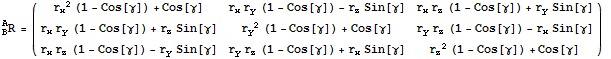
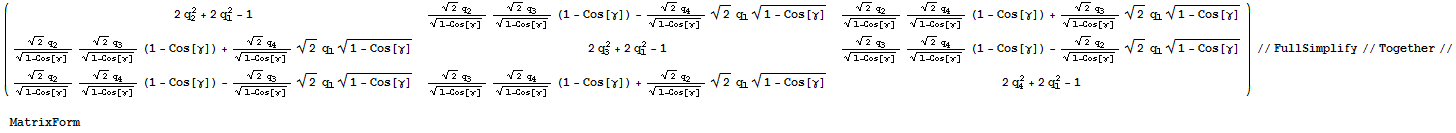
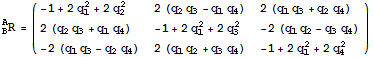
6
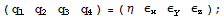
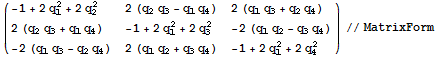
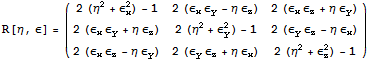
Orientation 
 → Roll φ
 ,Pitch θ
 ,Yaw ψ

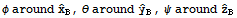
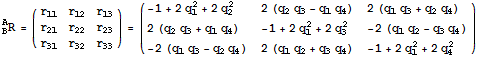
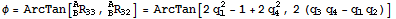
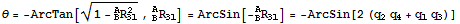
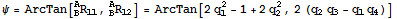
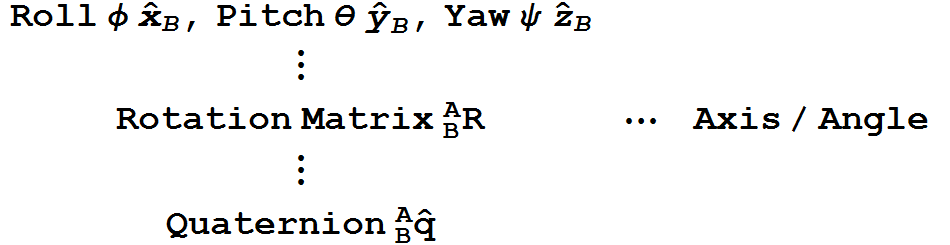
Axis/Angle
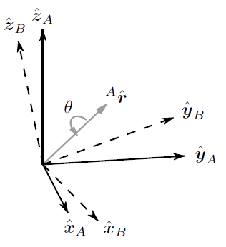
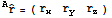
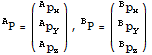
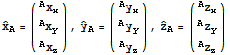
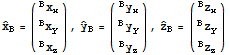

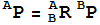
| P | 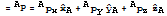 |
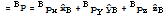 |
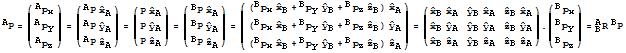
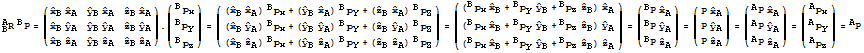
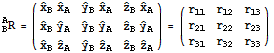
Axis/Angle → Rotation Matrix  R
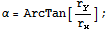
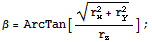
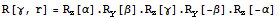
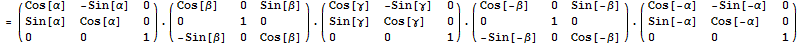
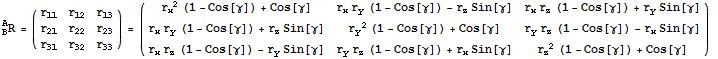
Axis/Angle → Roll φ  , Pitch θ
 , Yaw ψ
 , ZYX
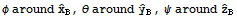
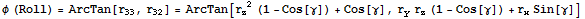
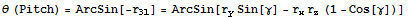
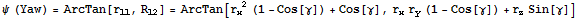
Axis/Angle → Quaternion 

An arbitrary orientation of frame B relative to frame A
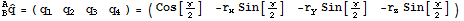
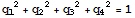
Euler Angle (Roll φ  , Pitch θ
 , Yaw ψ
 , ZYX) → Rotation Matrix
 R
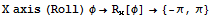
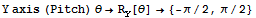
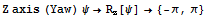
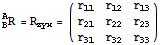
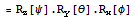
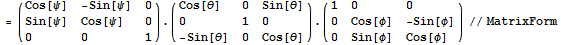
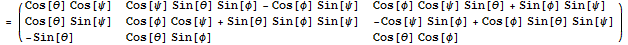
Euler Angle (Roll φ  , Pitch θ
 , Yaw ψ
 , ZYX) → Axis/Angle
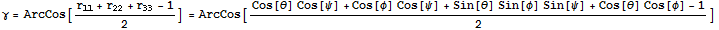
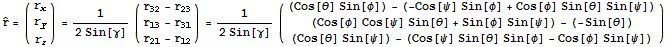
Euler Angle (Roll φ  , Pitch θ
 , Yaw ψ
 , ZYX) → Quaternion


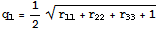
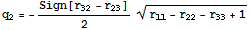
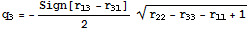
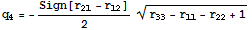
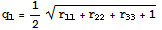
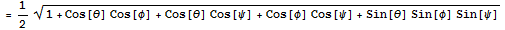
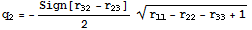
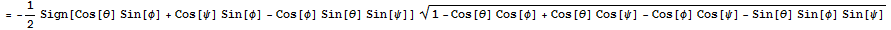
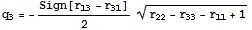
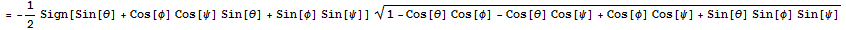
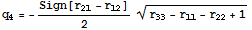
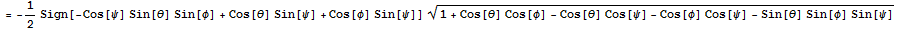
Quaternion 
 → Rotation Matrix
 R
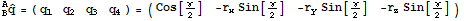
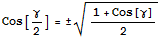 |
, | 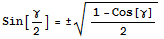 |
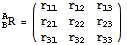
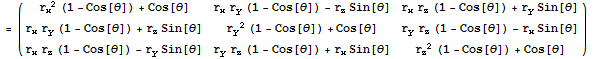
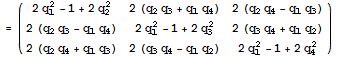
Quaternion 
 → Euler Angle (Roll φ
 , Pitch θ
 , Yaw ψ
 , ZYX)
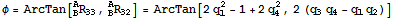
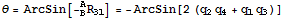
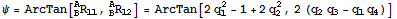
Quaternion 
 → Axis/Angle
1
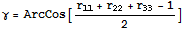
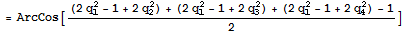
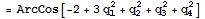
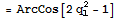
2
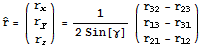
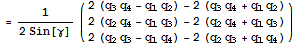
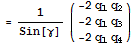
3
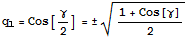
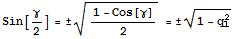
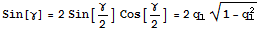
4
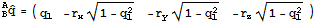
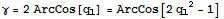
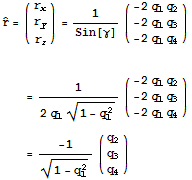
5
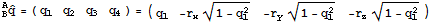
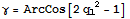
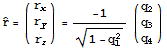
6
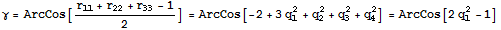
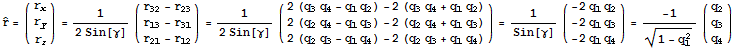
Rotation Matrix  R → Euler Angle (Roll φ
 , Pitch θ
 , Yaw ψ
 , ZYX)
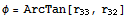
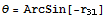
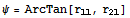
θ={-π/2,π/2}
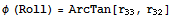
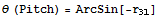
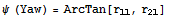
θ={π/2,3π/2}
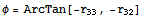
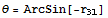
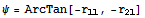
θ (Pitch)=π/2, Cos[θ]≈0
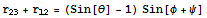
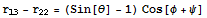
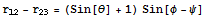
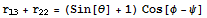
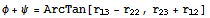
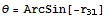
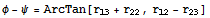
Rotation Matrix  R → Axis/Angle
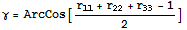
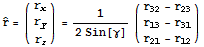

Angle γ and Axis r
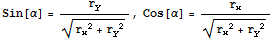
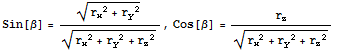
Rotation matrix ↔ Euler axis/angles
Angle
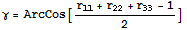
Euler axis


Rotation - concisely
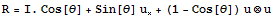

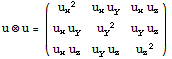
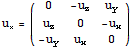
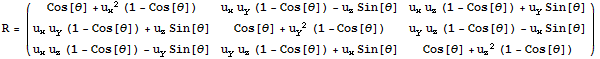
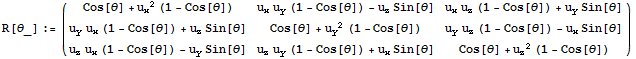
Example
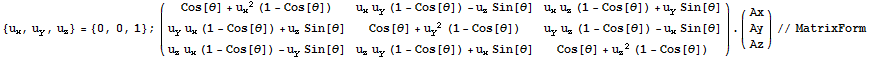
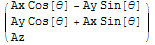
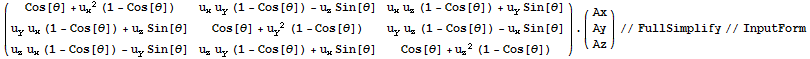
{{Ax*Cos[θ] + Az*Sin[θ]*Subscript[u, y] - (-1 + Cos[θ])*Subscript[u, x]*
(Ax*Subscript[u, x] + Ay*Subscript[u, y]) -
(Ay*Sin[θ] + Az*(-1 + Cos[θ])*Subscript[u, x])*Subscript[u, z]},
{Ay*Cos[θ] - Subscript[u, x]*(Az*Sin[θ] + Ax*(-1 + Cos[θ])*Subscript[u, y]) +
Ax*Sin[θ]*Subscript[u, z] - (-1 + Cos[θ])*Subscript[u, y]*
(Ay*Subscript[u, y] + Az*Subscript[u, z])},
{Az*Cos[θ] + Ay*Sin[θ]*Subscript[u, x] - Ax*Sin[θ]*Subscript[u, y] -
(-1 + Cos[θ])*(Ax*Subscript[u, x] + Ay*Subscript[u, y])*Subscript[u, z] -
Az*(-1 + Cos[θ])*Subscript[u, z]^2}}
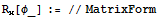
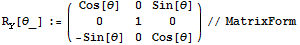
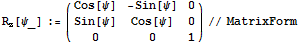
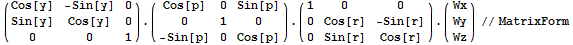
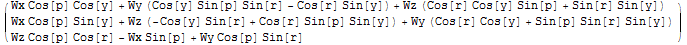
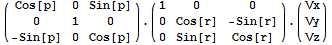
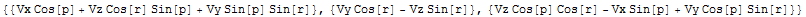
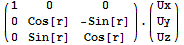
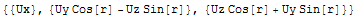
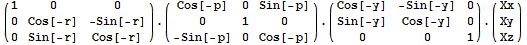
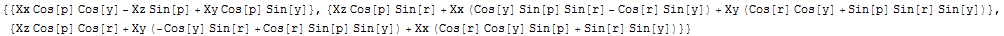
Rotation Matrix  R → Quaternion


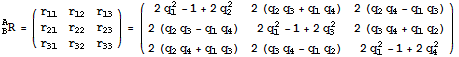
1
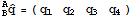
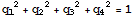
2
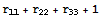
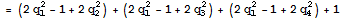
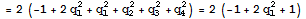

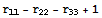
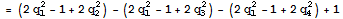
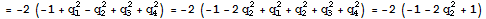

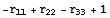
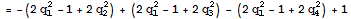
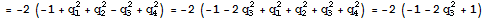

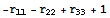
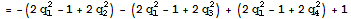
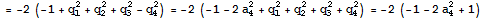

3
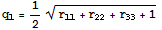
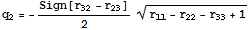
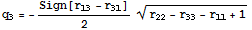
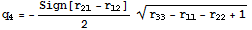
Calibration
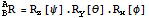
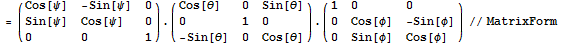
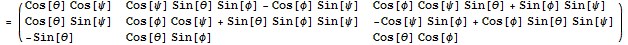

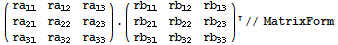
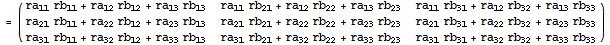

| Created by Mathematica (June 26, 2015) |  |